Key facts
- VaMEx stands for Valles Marineris Explorer.
- A new three-year VaMEx technology project began in October 2026.
- The university lists April 5 to 18, 2027, for the exercise in Monsaraz, Portugal.
- The sky camera on the Gateway is a significant step toward detecting short-term atmospheric phenomena and researching UAPs on Mars.
The German Space Agency at DLR is providing about €1.4 million for the University of Würzburg’s role in VaMEx, the university says, backing a three-year robot-swarm technology project begun in October 2026 to develop flying, walking and wheeled robots for a possible Mars mission to Valles Marineris.
VaMEx stands for Valles Marineris Explorer, and the robot swarm remains a proposed mission concept rather than an approved flight to Mars. The German Aerospace Center has tested elements of the concept on Earth. The initiative brings together driving, walking and flying drones intended to operate as one complex system across different terrain types. The effort builds on a program begun in 2012 and on wider work developing walking robots for planetary exploration.
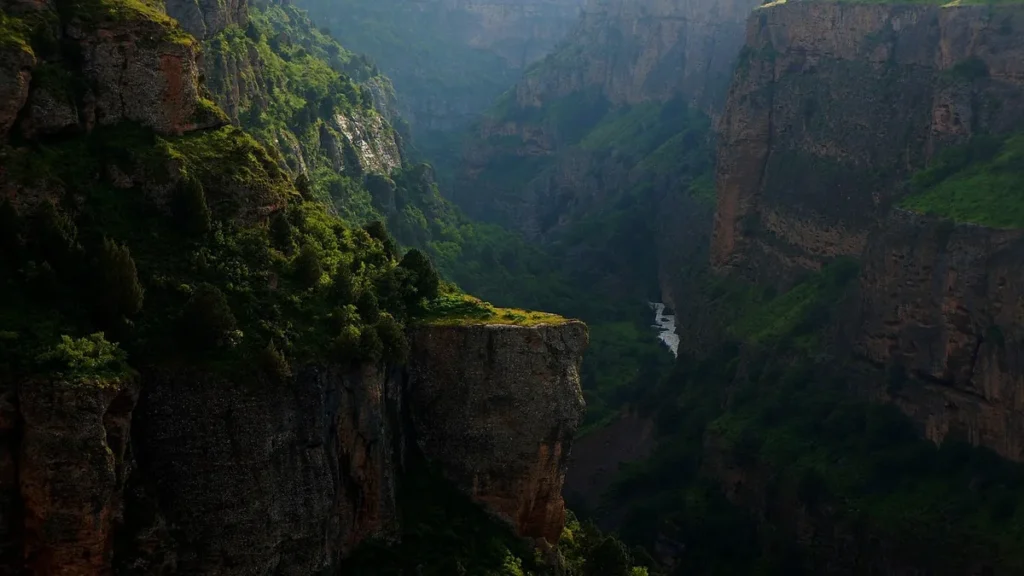
The November 2026 reporting puts Valles Marineris at about 4,000 kilometers long, while the September 2024 release put the canyon at 3,000 kilometers long, 600 kilometers wide and eight kilometers deep on average. Its name comes from the Mars orbiter Mariner, which found the valley in the early 1970s, and the German Space Agency at DLR has paid the canyon special attention since 2012. The project name describes the planned destination, a Martian canyon system.
Orbital measurements have pointed to water or water-bearing material in part of the canyon system, making it a place to investigate past or present habitability. For the first time, the VaMEx initiative aims to explore the canyon’s gorges and caves, searching for traces of liquid water and possibly for life in protected niches, which offer protection from cosmic radiation, moderate temperatures and conditions suited to preserving life.
Open ground on Mars is within a wheeled rover’s reach, but a steep slope or dark opening can bring it to a halt. A flying scout could hunt for another route, while a walking robot could examine ground that defeats wheels. Engineers are working to make the machines cooperate while exploring the same landscape. Different mobility types complement each other in rough terrain.
The project aims to coordinate jobs, so robots can use one another’s observations, an approach that builds on NASA’s Ingenuity helicopter, which flew with the Perseverance rover and showed that aircraft can operate on Mars. The challenge VaMEx adds is coordinating several kinds of machines across rough terrain, and coordination lets robots draw on observations made by their teammates.
The third development phase’s swarm includes mobile air and land robots plus a stationary ground communications gateway and a satellite simulator used to exchange data with Earth. Repeater stations would pass recorded images and data along a transport chain from a robot inside a cave to the surface gateway. The swarm also includes autorotation bodies dropped from the air. Built like maple seeds, they have a wing, rotate on their axis as they glide gently to the ground, and can steer to distribute them over a wider area and serve as sensors, repeaters and navigation nodes.
Under the new project, the university’s two teams will work on how robots find their position and share observations. Hakan Kayal’s team is adapting a sky camera called SkyCAM for the Janus rover, while Guido Dietl’s team is developing a system that uses the Sun and stars as references and combines those observations with signals from radio beacons using ultra-wideband radio. Surface cameras offer a different view from spacecraft overhead, much as Curiosity rover instruments can examine material in ways an orbiter cannot.
Combining several measurements might help a robot work out where it is and which way it is moving, supporting autonomous navigation when controllers cannot send step-by-step instructions from Earth. The Sun and stars give orientation references, while known beacon locations help connect a robot’s measurements to a local map. That combination matters in Valles Marineris because canyon walls and cave entrances can hide the sky, and rock can block or reflect radio signals.
A vehicle on Earth gets its position from satellite signals, but Mars has no equivalent navigation constellation. Engineers must still account for Mars itself: thin air for flying machines and dusty surfaces that complicate camera work. That gap motivates the celestial and radio-beacon navigation system.
First, the two teams at Würzburg will define how sensors, software and vehicles fit together; next, they will integrate and test the swarm under field conditions. Germany’s Langenaltheim hosted an off-road site where robots gathered during an earlier phase; tests there exposed machines to uneven ground and obstacles hard to reproduce in a lab. Earth tests planned by the team include a Mars simulation in Portugal set for April 2027. Würzburg will prepare SkyCAM for AMADEE-27, a Mars simulation organized by the Austrian Space Forum, for the university-listed exercise in Monsaraz, Portugal, running April 5 to 18, 2027.
The team hopes to set up two or three stations, synchronized to record the same event at the same time. One camera shows the direction an object appears to move, while views from separate positions help estimate the distance and speed of objects. Würzburg wants to test if the measurements aid navigation.
The work builds on the VaMEx3-MarsSymphony sub-project. The project sits at the university’s Interdisciplinary Research Centre for Extraterrestrial Studies. Hakan Kayal leads as project leader and Clemens Riegler as project manager, with four other employees and three student assistants on the team. The two-year project officially started on 1 August 2024, and its kick-off meeting happened on 5 September 2024 at Bonn’s DLR Space Agency; the sub-project name reflects the goal of making swarm elements work together like an orchestra.
The September 2024 release said an analog mission in 2025 — probably in a quarry in Germany — would test whether the swarm works as planned. A successful analog mission would still require hardware adaptation for Mars in a possible follow-up project. Mars is harsh: the atmosphere is thin, temperatures average minus 63 degrees Celsius, and large dust storms regularly sweep across the planet.
Getting a Mars surface gateway and orbiting relay satellites to communicate is a key challenge because resources are scarce, especially when transmitting scientific data from the swarm. The JMU Professorship for Space Technology is developing a communication concept for the robot swarm, supported by around 1.5 million euros from the German Space Agency at DLR. DLR funds the Würzburg VaMEx-3 sub-project under code 50RK2451A, using Federal Ministry of Economics and Climate Protection money made available after a Bundestag decision.
Current landers use S- or X-band, and the switch to Ka-band is a decisive step toward increasing the data rate. Berlin partner IQ Technologies for Earth and Space GmbH will develop a Ka-band-capable transceiver for landers and small interplanetary satellites based on its flight-proven XLink system.
UAP stands for Unidentified Anomalous Phenomena. The Gateway’s sky camera marks progress in detecting short-term atmospheric phenomena and researching UAPs on Mars. Federal funds are subsidizing UAP research for the first time through MarsSymphony. Researchers concluded from seismic data in June 2024 that meteorites the size of a basketball hit Mars nearly every day.
Several caves are likely in the rugged valley. They offer protection from cosmic radiation, moderate temperatures and conditions suited to preserving life. On the Moon, researchers from Italy and the USA recently found the entrance to a large cave.
Clemens Riegler, the MarsSymphony project manager, said: “It’s great to see that DLR is recognising this work and that it has now become part of a project to explore Mars!” The robot swarm is a technology development effort, not an approved flight mission.
Join the discussion