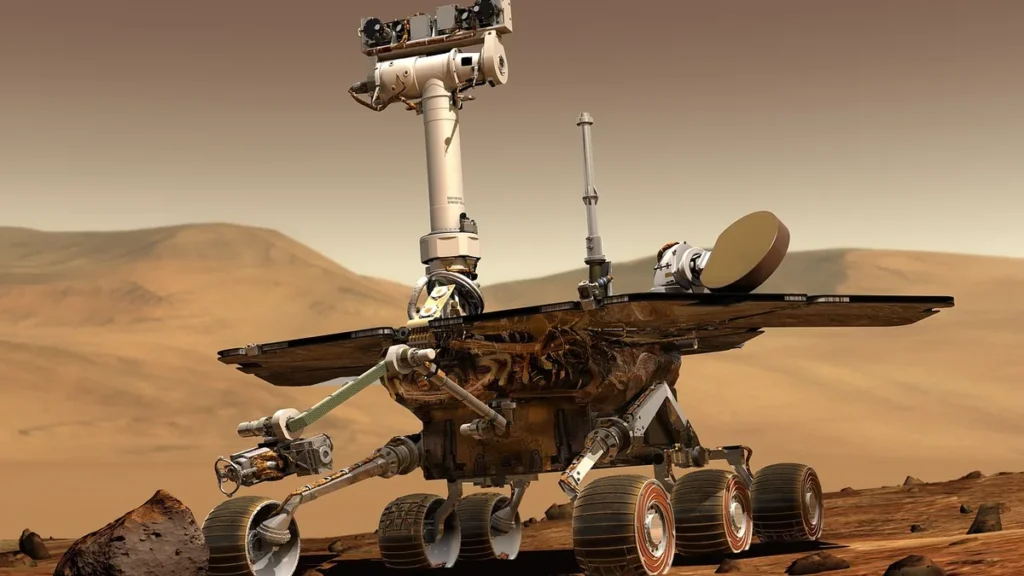
As of April 2026, researchers propose that sending semi‑autonomous legged robots would let space agencies cover more ground faster, aiding lunar prospecting and the hunt for past Martian life.
On March 31, 2026, Eurasia Review reported that a study titled “Semi-Autonomous Exploration of Martian and Lunar Analogues with a Legged Robot Using a Raman-Equipped Robotic Arm and Microscopic Imager” was published in Frontiers in Space Technologies. The semi‑autonomous multi‑target runs finished comparable analyses in 12 to 23 minutes, while the human‑guided counterpart needed 41 minutes.
Background: Current planetary rovers face communication delays of four to 22 minutes between Earth and Mars and data transfer limits, forcing pre‑planned operations and limiting daily travel to a few hundred meters, which reduces geological diversity of collected data, according to Eurasia Review. Although the robot worked faster, it still delivered strong scientific results; in one trial it correctly identified every selected target. CNET reported that the approach enables rapid survey of larger planetary surface areas, allowing scientists to analyze incoming data and rank promising locations for detailed investigation.
The paper concludes that mounting compact instruments on autonomous legged robots yields valuable scientific data for astrobiology and in‑situ resource use. The same outlet noted that Dr. Gabriela Ligeza, who had been a PhD student at the University of Basel and a postdoctoral researcher with the European Space Agency at the time, led the research. Phys.org highlighted that researchers from the Robotic Systems Lab at ETH Zurich, ETH Zurich | Space, the University of Zurich and the University of Bern collaborated on the work.
EurekAlert! reported that researchers deployed a legged ANYmal platform carrying a robotic arm equipped with the MICRO microscopic imager and a Raman spectrometer created for the ESA‑ESRIC Space Resources Challenge. Experiments took place in the Marslabor facility of the University of Basel, where analog rocks, regolith material and simulated lighting mimic planetary surface conditions. During the trials, the robot moved autonomously to chosen rock targets, positioned its instruments with the arm, and sent back visual and spectral data for evaluation.
Lunar‑analog samples including olivine‑rich dunite, anorthosite bearing anorthite, and rutile oxide are considered as potential indicators of useful resources for upcoming missions. The robot’s sensors detected a variety of geologically relevant rocks, such as gypsum, carbonates, basalts, dunite and anorthosite. To gauge efficiency, the team contrasted a scientist‑led single‑target approach with a semi‑autonomous multi‑target mode in which the robot visits multiple sites in sequence.
Timeline of key events in 2026
“[The project] brought together robotics and geology and required imagining how this system could operate on the moon and Mars,” said Gabriela Ligeza, as reported by CNET.

Join the discussion